1
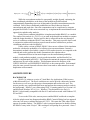
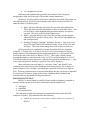
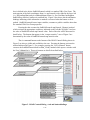
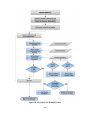
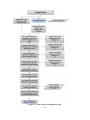
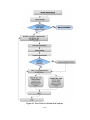
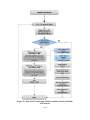
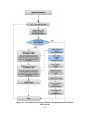
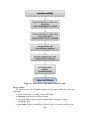
on a given road segment as a function of the traffic and geometric characteristics of the
roadway. Given an encroachment has occurred, the crash prediction module then
assesses if the encroachment is likely to result in a crash, P(Cr|Encr). If a crash is
predicted, the severity prediction module estimates the severity of the crash, P(Sev|Cr).
The severity estimates of each crash are then calculated and transformed into units of
dollars in order to compare the reduction in societal crash costs (i.e., benefits) to the
direct cost of implementing the alternative (i.e., costs). The following conditional
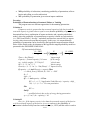
probability model is used for each alternative on each segment:
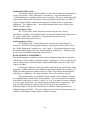
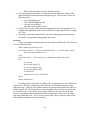
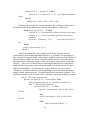
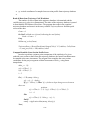
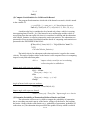
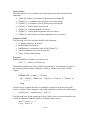
E(CC)N,M = ADT · LN · P(Encr) ∙P(Cr|Encr) ∙ P(Sev|Cr) ∙ E(CCs|Sevs)
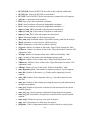
where:
E(CC)N,M
AADT
LN
P(Encr)
P(Cr|Encr)
P(Sevs|Cr)
E(CCs|Sevs)
=
=
=
=
=
Expected annual crash cost on segment N for alternative M,
Average Daily Traffic in vehicles/day,
Length of segment N in miles,
The probability a vehicle will encroachment on the segment,
The probability a crash will occur on the segment given that an
encroachment has occurred,
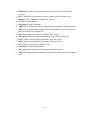
= The probability that an crash of severity s occurs given that a crash
has occurred and
= The expected crash cost of a crash of severity s in dollars.
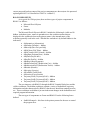
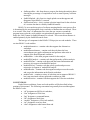
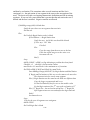
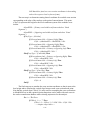
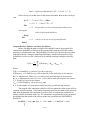
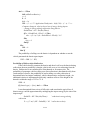
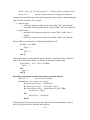
The term ADT·L·P(Encr) yields the expected number of encroachments on a
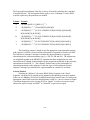
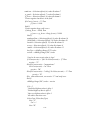
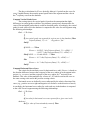
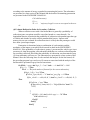
segment in units of encroachments/mi/year. ADT·P(Encr) can be further defined as:
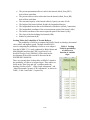
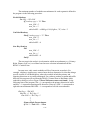
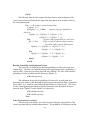
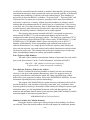
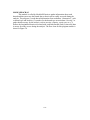
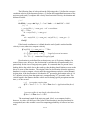
∙
∙
where the terms are as defined before and fbase encr is the base encroachment rate in units
of encroachments/mi/yr and EAFi are encroachment adjustment factors. fbase encr is
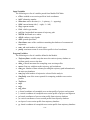
tabulated on the “Encr Freq and Adj” worksheet in RSAPv3 as are the encroachment
modification factors, EAFi. These values are simple lookup tables where the appropriate
adjustment or base encroachment is read from the tables given the geometric and traffic
characteristics of the highway provided by the user.
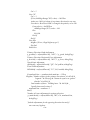
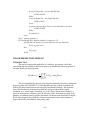
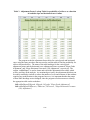
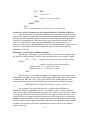
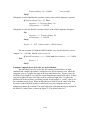
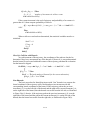
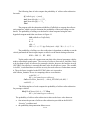
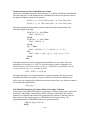
The collision and severity conditional encroachments, P(Cr|Encr) ∙ P(Sevs|Cr),
must be grouped together because each encroachment could have multiple events with
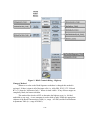
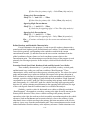
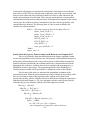
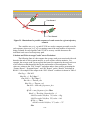
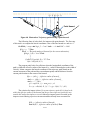
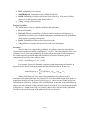
different severities. P(Cr|Encr) ∙ P(Sevs|Cr) can be expanded to:
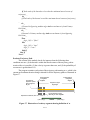
|
|
1
∩
|
|
∩
Where
∩
is the probability that trajectory k will intersect hazard j and the
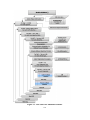
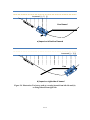
summation is done over all hazards and all trajectories. RSAPv3 will typically process
tens of thousands of trajectories for each segment to arrive at this summation. Each
trajectory analyzed is compared to every hazard identified by the user for each
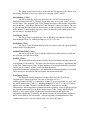
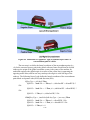
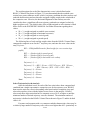
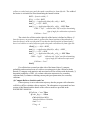
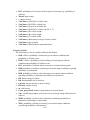
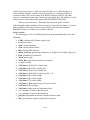
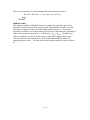
alternative. Lastly the expected crash cost of a severity s crash, E(CCs|Sevs), is multiplied
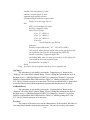
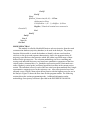
by the result to convert the result to units of dollars. Combining all the terms yields:
C-6