1
Motion Move Instructions
3-63
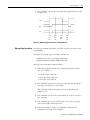
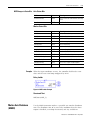
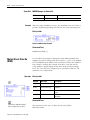
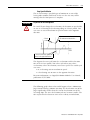
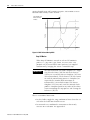
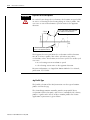
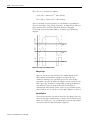
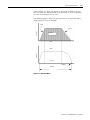
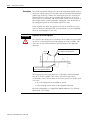
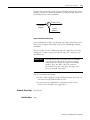
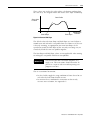
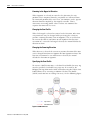
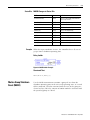
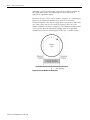
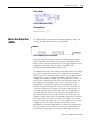
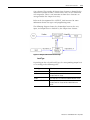
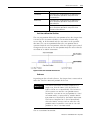
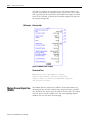
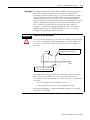
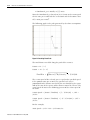
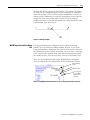
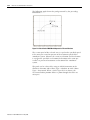
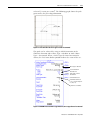
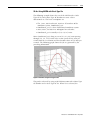
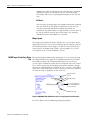
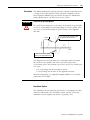
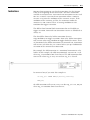
between these two and is used to drive the motor to make the actual
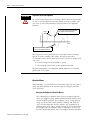
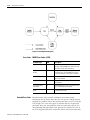
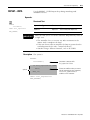
position equal to the command position. The Figure below shows the
relationship of these three positions.
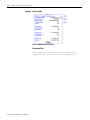
+
Command
Position
Position Error
–
Actual
Position
Figure 3.20 Position Relationship
See the Motion Axis Object specification for a more detailed overview
of the Nested Digital Servo Loop used by the ControlLogix motion
controllers.
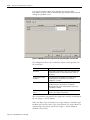
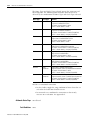
To successfully execute a MRP instruction, the targeted axis must be
configured as either a Servo or Feedback Only axis. Otherwise, the
instruction errs.
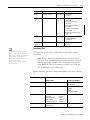
IMPORTANT
The MRP instruction execution may take multiple
scans to execute due to the fact that it requires
transmission of multiple messages to the motion
module. Thus, the Done (.DN) bit is not set
immediately, but only after these messages have
been successfully transmitted.
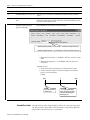
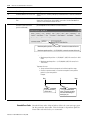
This is a transitional instruction:
• In relay ladder, toggle the rung-condition-in from cleared to set
each time the instruction should execute.
• In structured text, condition the instruction so that it only
executes on a transition. See Appendix C.
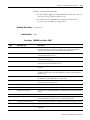
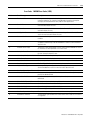
Arithmetic Status Flags: not affected
Fault Conditions: none
Publication 1756-RM007G-EN-P - May 2005