1
Operating Notes
2.6.2
Joystick Response Definition Tables
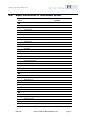
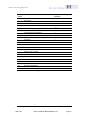
Normally the joystick response is defined by loading a predefined response table
using the JT command. The loaded response table will remain chosen even when
the controller is reset.
For special purposes, it is possible to generate a user-defined joystick response
table.
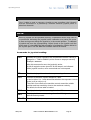
Commands for user-defined joystick tables (see Command Reference section for
more details):
SIn
Sets Index pointer for joystick table.
A new table value can then be written with the SJ command.
SI?
Report command asking for the current index value
SJn
Sets the table value at active index to n.
Range of n : 0 to 1024
Value 1024 represents maximum velocity, 0=standstill.
SJ?
Report command asking for the current table entry.
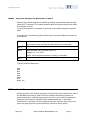
Typical Command Sequence:
SI0
SJ0
SI1
SJ5
SI2
SJ10
SI3
SJ15 etc.
2.7
Limit Sensors
During operation, limit sensors (switches) can be used to stop motion at the end of
the allowable travel range. Each of the two switches will interrupt motion in a
particular direction. If positioning equipment from PI is used, the limit switches or
sensors are pre-wired for operation with compatible Mercury™ controllers.
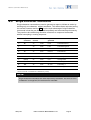
The Mercury™ controller can be configured to accept either an active-high or an
active-low stop signal from the limit sensors (both must be the same).
www.pi.ws
Native Commands MS176E Release 1.0.1
Page 11