1
Chapter 6
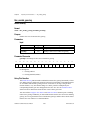
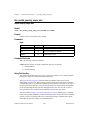
Trajectory Control Functions — flex_read_dac and flex_read_dac_rtn
Using This Function
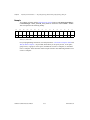
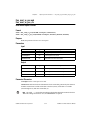
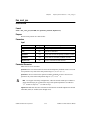
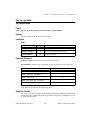
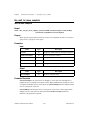
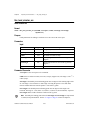
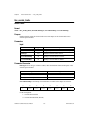
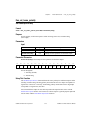
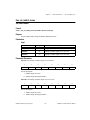
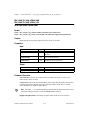
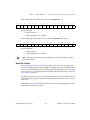
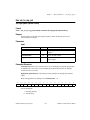
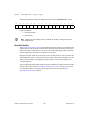
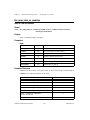
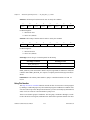
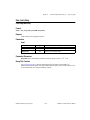
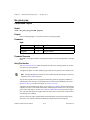
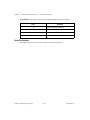
The Read DAC function returns the value of the specified DAC output. When sent to an axis,
this function returns the value of the primary DAC mapped to that axis. The signed 16-bit
value returned corresponds to the ±10 V full scale range of the DAC.
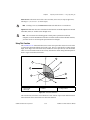
This function is used to monitor the output command from the PID loop. When the DAC
output is connected to a torque block servo amplifier, you can use this value to calculate motor
torque or to monitor the acceleration and deceleration portions of a trajectory to see how close
the control loop is to saturating at its maximum torque limits.
When the DAC output is connected to a velocity block servo amplifier, the DAC value read is
a direct representation of the instantaneous commanded velocity.
FlexMotion Software Reference Manual
6-94
www.natinst.com