1
Manual Stair Robot SR1750 HE
AATA INTERNATIONAL B.V.
Publication: 29-07-04
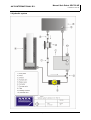
2. 6. Descent adjuster
•
•
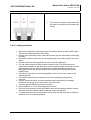
The descent adjuster is located at the rear end of
the machine and is used to adjust the descent of
the lifting platform depending on the weight of the
load.
Turn maximum clockwise for speed : 0
2.7. Hydraulic motor and pump
•
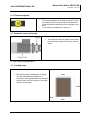
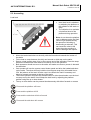
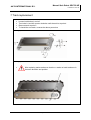
The hydraulic-motor is placed on the drive
motor with the pump built directly onto the
motor
3. Ancillary equipment
3.1. Loading ramp
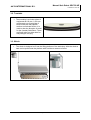
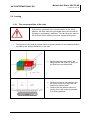
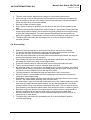
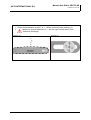
• The loading ramp is designed to fit neatly
into the stairrobots lifting platform. It
provides a safe ridged platform to transport
the load from the floor-surface to the loadposition on the robot.
Page 9 of 28