1
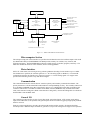
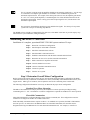
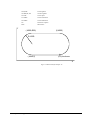
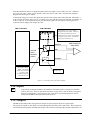
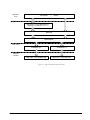
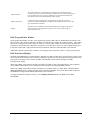
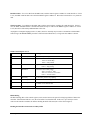
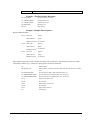
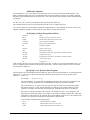
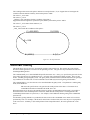
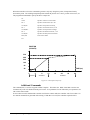
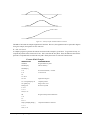
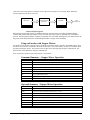
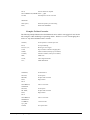
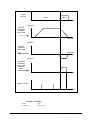
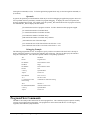
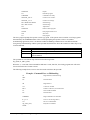
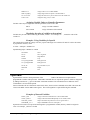
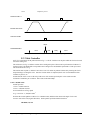
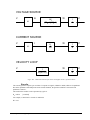
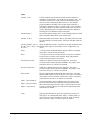
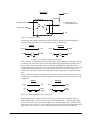
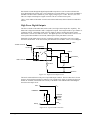
value of the step count register as well as the value of the reference position. For example, DP 0, defines the
reference position of the X axis to be zero.
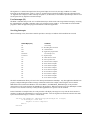
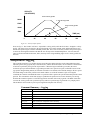
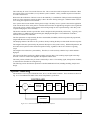
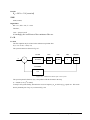
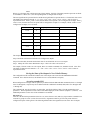
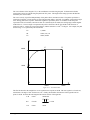
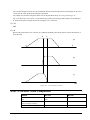
Stepper Smoothing Filter
(Adds a Delay)
Motion Profiler
Reference Position (RP)
Output
(To Stepper Driver)
Output Buffer
Step Count Register (TD)
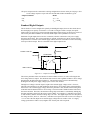
Motion Complete Trippoint
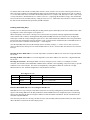
When used in stepper mode, the MC command will hold up execution of the proceeding commands until the
controller has generated the same number of steps out of the step count register as specified in the commanded
position. The MC trippoint (Motion Complete) is generally more useful than AM trippoint (After Motion) since the
step pulses can be delayed from the commanded position due to stepper motor smoothing.
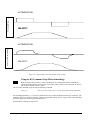
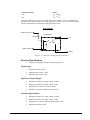
Using an Encoder with Stepper Motors
An encoder may be used on a stepper motor to check the actual motor position with the commanded position. If an
encoder is used, it must be connected to the main encoder input. Note: The auxiliary encoder is not available while
operating with stepper motors. The position of the encoder can be interrogated by using the command, TP. The
position value can be defined by using the command, DE.
Note: Closed loop operation with a stepper motor is not possible.
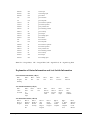
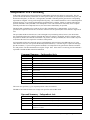
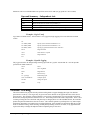
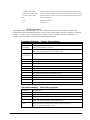
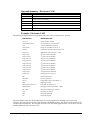
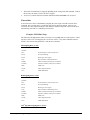
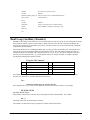
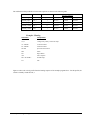
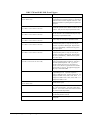
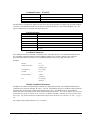
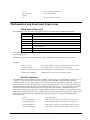
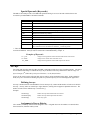
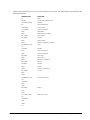
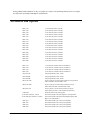
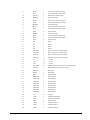
Command Summary - Stepper Motor Operation
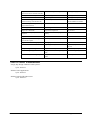
COMMAND
DESCRIPTION
DE
Define Encoder Position (When using an encoder)
DP
Define Reference Position and Step Count Register
IT
Motion Profile Smoothing - Independent Time Constant
KS
Stepper Motor Smoothing
MT
Motor Type (2,-2,2.5 or -2.5 for stepper motors)
RP
Report Commanded Position
TD
Report number of step pulses generated by controller
TP
Tell Position of Encoder
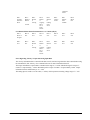
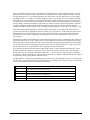
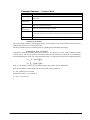
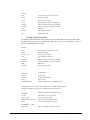
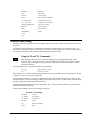
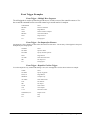
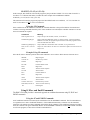
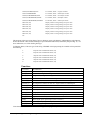
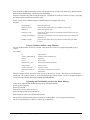
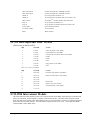
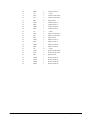
Operand Summary - Stepper Motor Operation
OPERAND
DESCRIPTION
_DEx
Contains the value of the step count register for the ‘x’ axis
_DPx
Contains the value of the main encoder for the ‘x’ axis
_ITx
Contains the value of the Independent Time constant for the ‘x’ axis
_KSx
Contains the value of the Stepper Motor Smoothing Constant for the ‘x’ axis
_MTx
Contains the motor type value for the ‘x’ axis
_RPx
Contains the commanded position generated by the profiler for the ‘x’ axis
_TDx
Contains the value of the step count register for the ‘x’ axis
_TPx
Contains the value of the main encoder for the ‘x’ axis
118 • Chapter 6 Programming Motion
DMC-1700/1800