1
6. COMMAND REFERENCE
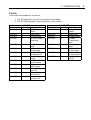
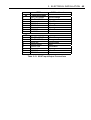
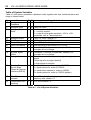
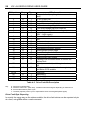
Status Bits
Bit Number
9
10
16
23
24
25
26
Status Information
Motor energised
Motor undefined, use MOTOR command
Duty cycle too high, excessive motor current (I2t)
Tracking limit is greater than max. allowed position error
Last SETUPFB command failed
In motion, 0 for positive motion, 1 for negative motion
Brake applied, goes to a 1 if the brake is engaged
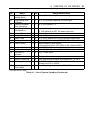
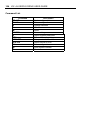
User Faults
Bit Number
1
2
8
16
19
22
23
26
27 to 32
UF Information
Value is out of range
Incorrect command syntax, command has
wrong format
Drive de-energised
Transmit buffer overflow*
Drive not ready
Save/restore error
Command not supported by this product
Cannot execute motion as the brake is
engaged
Reserved
*sends an ASCII ‘bell’ character to indicate a buffer overflow condition.
103