1
PMSM field oriented control
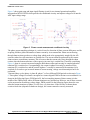
The observer is applied to PMSM motor with an estimator model excluding the extended BEMF term.
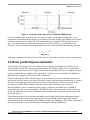
Then the extended BEMF term can be estimated using the observer as shown in Figure 7, which uses a
simple observer of PMSM stator current. The BEMF observer presented here is realized within the
rotating reference frame (dq). The estimator of dq-axis consists of the stator current observer based on
RL motor circuit with estimated motor parameters. This current observer is fed by the sum of the actual
applied motor voltage, cross-coupled rotational term, which corresponds to the motor saliency (Ld-Lq),
and compensator corrective output. The observer provides BEMF signals as disturbance because BEMF
is not included in the observer model.
Figure 7. Luenberger type stator current observer acting as state filter for BEMF
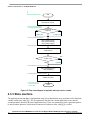
To obtain the speed and position information from the position error, another algorithm ‘A tracking
observer’ is used. This algorithm adopts the phase-locked loop mechanism. It requires a single input
argument as phase error. Such phase tracking observer, with standard PI controller used as the loop
compensator is shown in Figure 8.
Figure 8. Block diagram of proposed PLL scheme for position estimation
3-phase Sensorless PMSM Motor Control Kit with MagniV MC9S12ZVM Application Note Rev. 0 05/2015
10
Freescale Semiconductor, Inc.