1
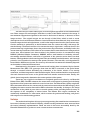
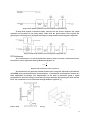
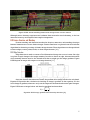
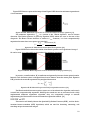
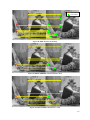
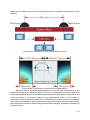
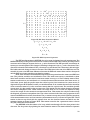
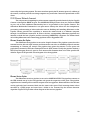
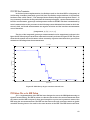
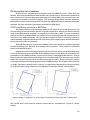
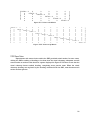
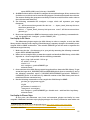
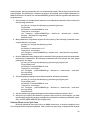
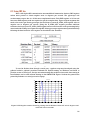
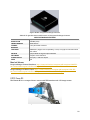
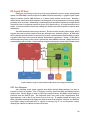
shifted by the length of the baseline. Figure III.III provides a graphical representation of this
property.
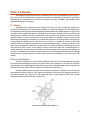
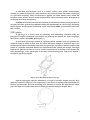
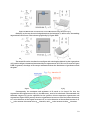
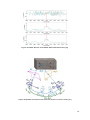
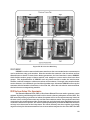
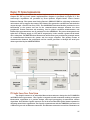
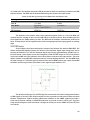
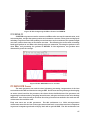
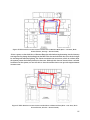
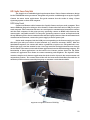
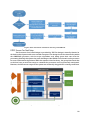
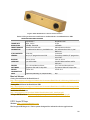
Figure III.II: General Stereoscopic Camera Implementation
Figure III.III: Correspondence between Left and Right Images
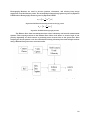
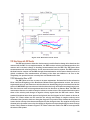
This local shift of equivalent pixels between the left and right image frames is the
fundamental property that allows for depth, or Z-vector, calculations to be later produced. By
comparing the equivalent pixel movements from the frames of the next discrete time constant, the
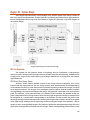
overall movement of the camera system can be approximated within its local frame. A
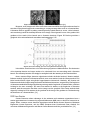
stereoscopic camera system will usually have to calibrate the two frames before any processing
can be done. The calibration aligns the frames such that they fall within the same horizontal axis.
The calibration also serves to remove image distortion due to warping, and find the parameters of
the camera pairs.
23